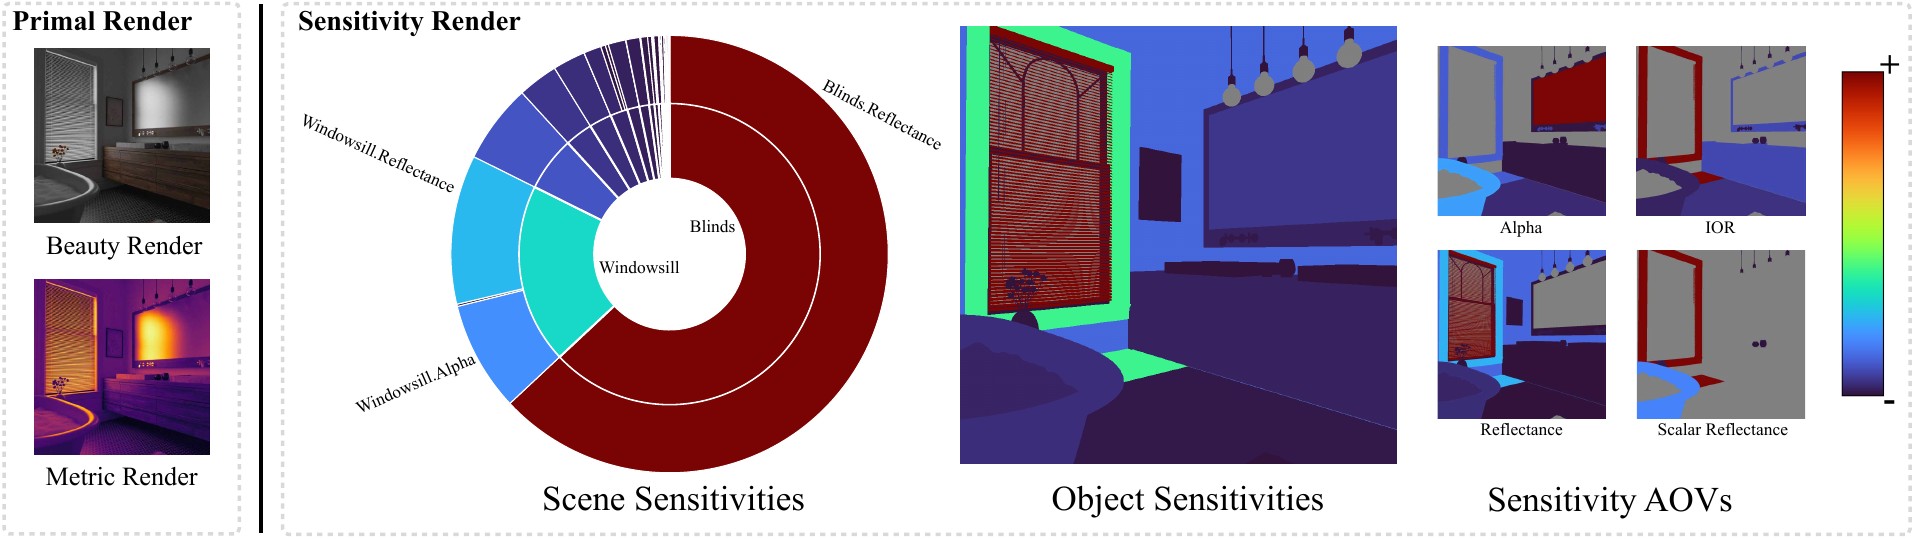
Differentiable renderers expose the derivative of any scalar objective with respect to every scene parameter, yet unlike the primal image, which decades of arbitrary output variables (AOVs) have taught us to decompose, inspect, and composite, these derivatives have no established representation for human inspection. We introduce the sensitivity AOV, a render output carrying the sensitivity of an objective to the scene parameters that influence it. A single reverse-mode pass populates a sensitivity buffer over the scene's parameter hierarchy, from which many views are read rather than re-differentiated, in direct analogy to deferred shading: image-space sensitivity at object and parameter-type granularity, projections onto a freely navigable scene from any inspection viewpoint, and, for spatially varying parameters, per-texel fields carried to the surface through texture coordinates. We separate the fixed camera that defines the objective from the free camera used to inspect the result, and position reverse-mode attribution against its forward-mode dual. Our aim is not a single algorithm but a scaffolding that establishes derivative outputs as first-class render products alongside the primal image.
Sensitivity as an Arbitrary Output Variable for Differentiable Rendering
SIGGRAPH Asia Technical Communications, 2026
Abstract